Mars Rover Manipulator
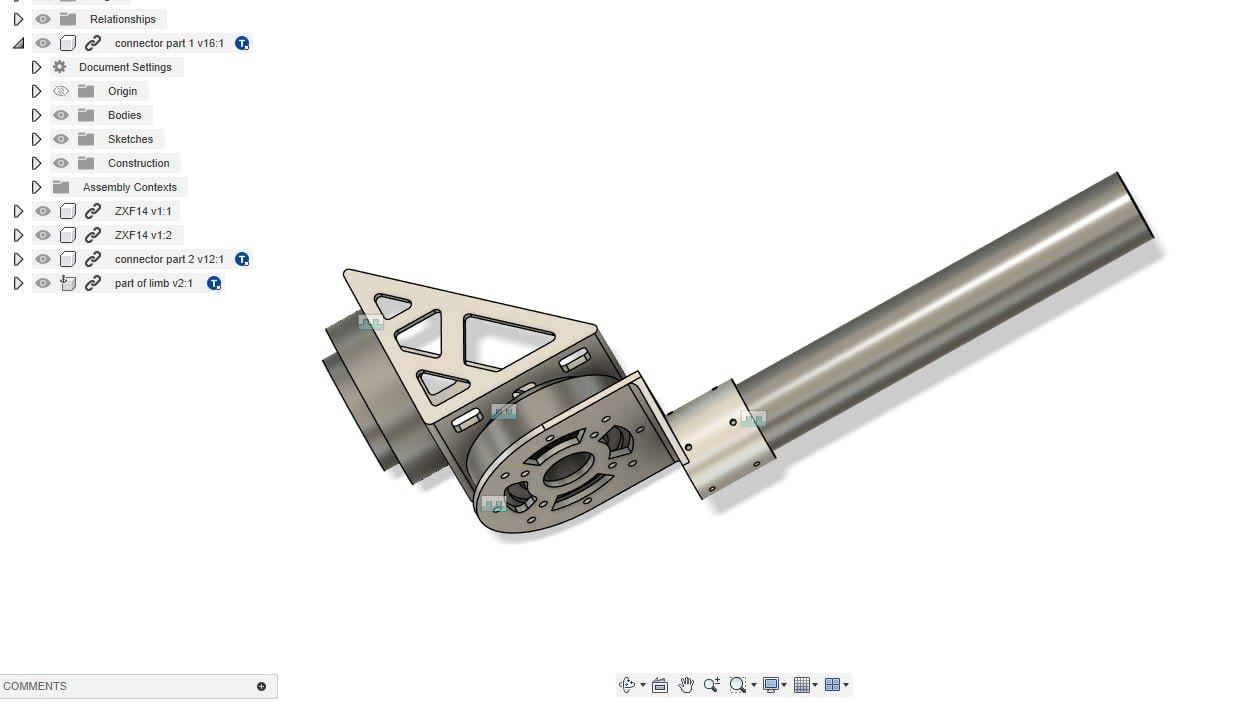
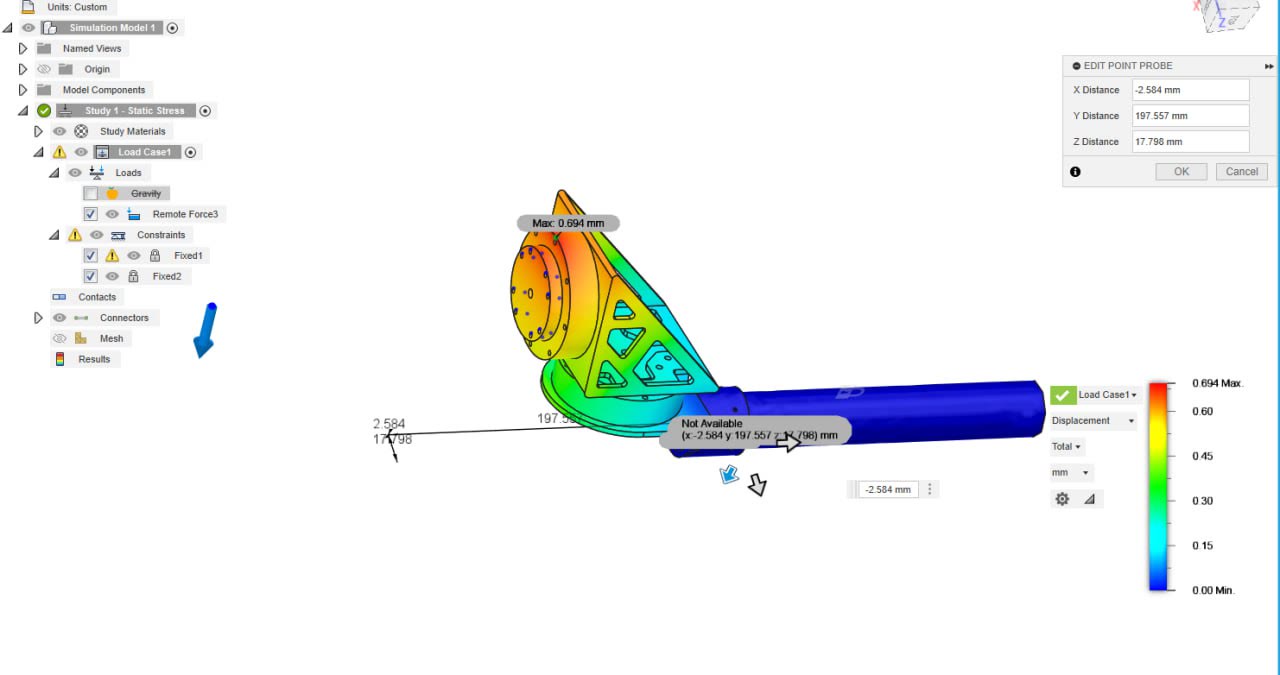
I designed components for a lightweight six-axis rover arm, using stress simulation with a factor of safety of 5. I also developed and simulated Python control logic and contributed to mechanical assembly for arm integration.
Objective: Support the development of a lightweight rover manipulator by balancing structural rigidity and mass, while contributing to the control and mechanical integration of the arm.
My role: Component design, control simulation and mechanical assembly. European Rover Challenge · SETU research project. Supervisor: Andrew Keppel.
My contribution: Designed components in SolidWorks and Fusion 360. Used stress simulation to assess rigidity and mass with a factor of safety of 5. Developed and simulated Python control logic. Contributed to mechanical assembly to support arm integration.
Mechanical design: SolidWorks and Fusion 360 supported component design for the six-axis arm. My role focused on components within the wider university rover project.
Structural assessment: Stress simulation informed the balance between rigidity and mass. The CV reports a factor of safety of 5; the loading assumptions and component-level results are not yet included here.
Control and assembly: I developed and simulated control logic in Python and contributed to mechanical assembly, connecting the design work with the arm’s integration.
Scope: The factor of safety relates to the reported stress-simulation work. Payload, positioning accuracy, physical load testing and competition performance are not documented here, so no claims are made about those outcomes.
Technologies
- SolidWorks
- Fusion 360
- Stress simulation
- Python
- Mechanical assembly