Final-year Robotics Student | Dynamics, Control and Underactuated Systems
I’m a final-year Robotics and Automated Systems student at South East Technological University in Carlow, Ireland. My work brings together mathematical modelling, nonlinear simulation, mechanical design and embedded control. I’m interested in how physical models inform the design and control of robotic systems, particularly underactuated systems. My current final-year project investigates controlled tipping and balance using a single gimbaled reaction wheel. I’m preparing for Master’s study in robotics and control, building on projects in rover manipulation, vision-based navigation and programmable electronics. Contact: tfliorko@gmail.com.
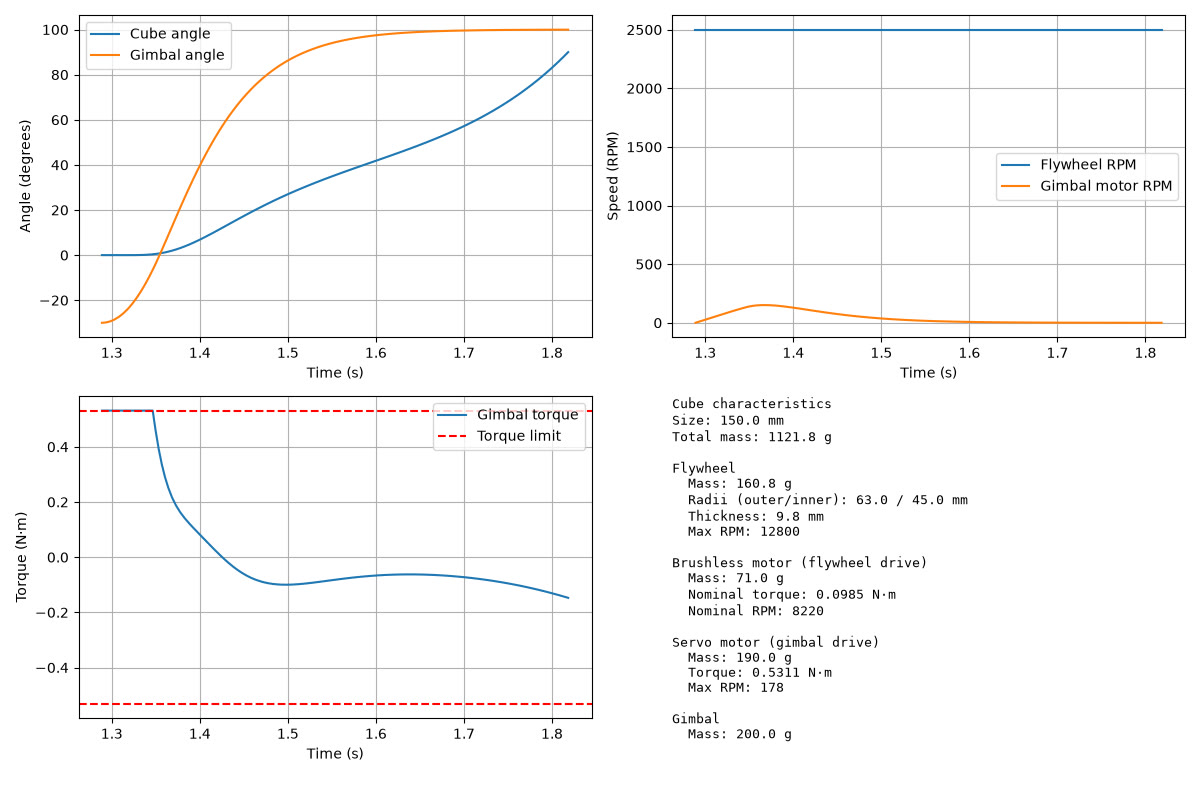
Simulation and optimisation software for defining the technical specification of a gimbaled reaction wheel cube. Evaluated 19,088 simulated cases across 157 flywheel geometries and developed a weighted design-ranking algorithm.
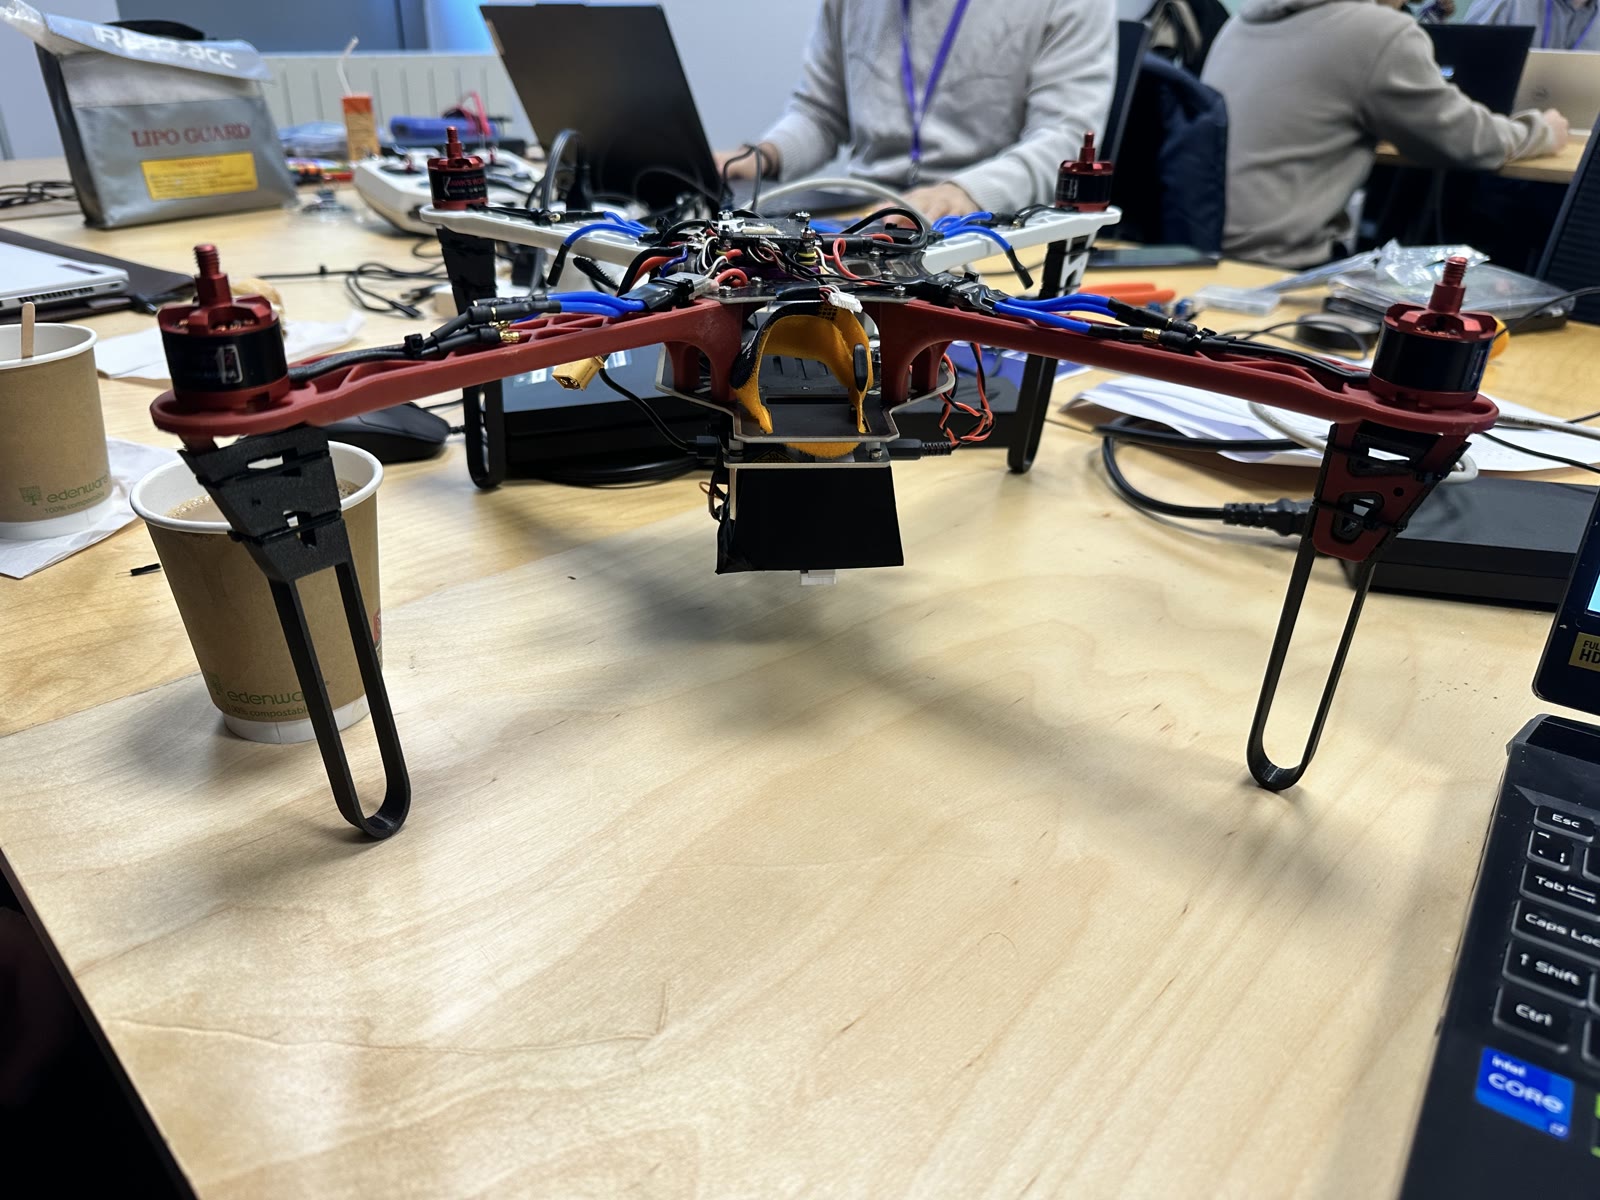
Co-developed stereo-vision navigation using optical flow, least squares estimation and Kalman filtering. Validated navigation on real data and contributed to drone integration with a team that reached the EUDIS Defence Hackathon Ireland finals.
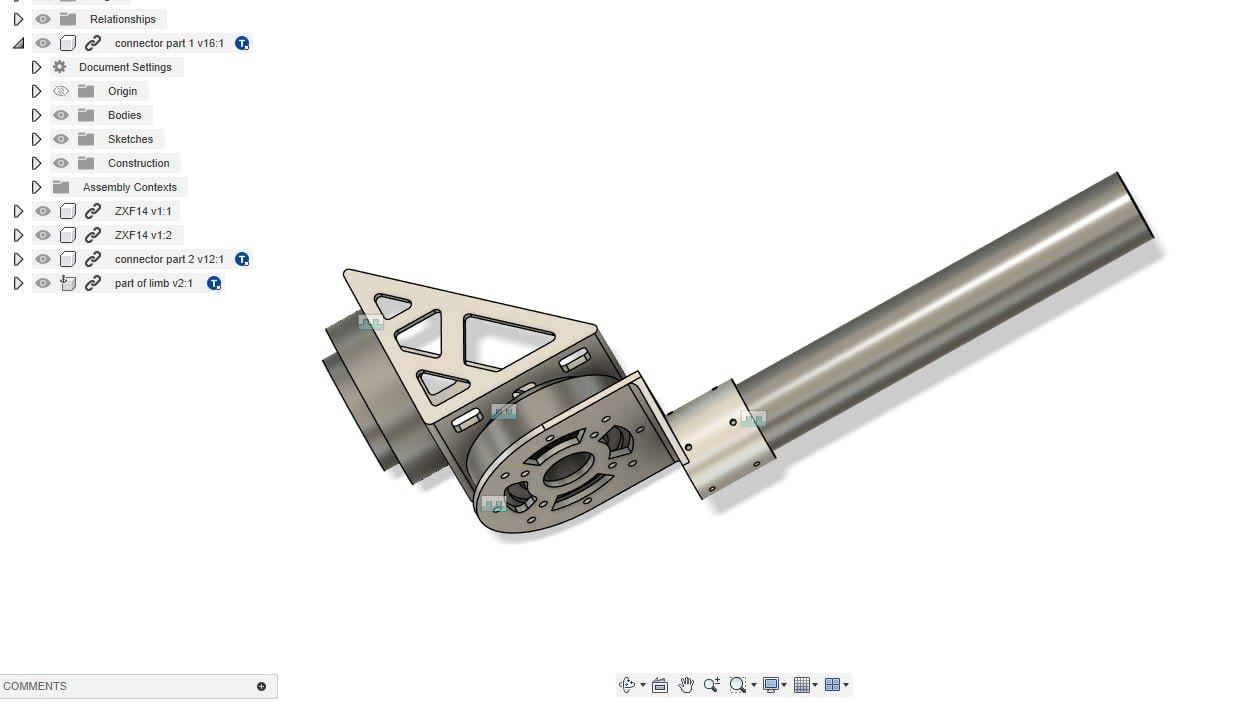
Designed components for a lightweight six-axis rover arm, evaluated structural behaviour through stress simulation, and developed Python control logic for the SETU European Rover Challenge project.
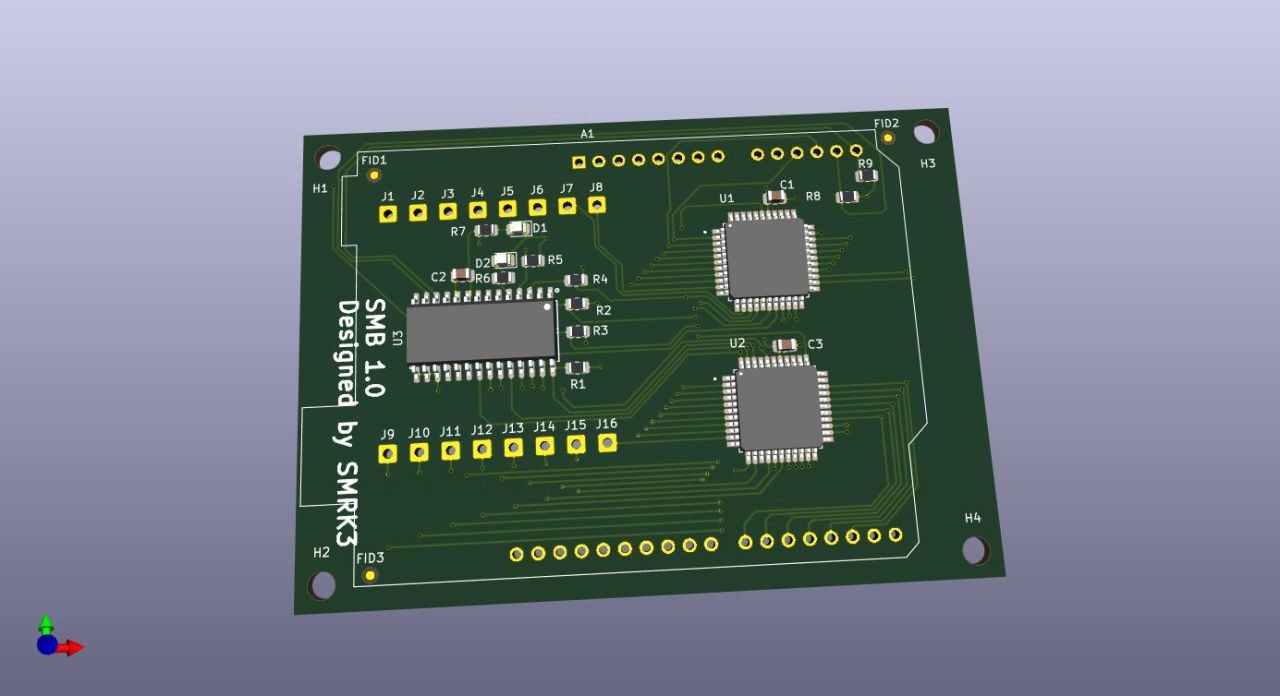
Designed a software-configurable breadboard with two MT8816 switch matrices, 256 programmable crosspoints, a custom KiCad PCB and Arduino control firmware.
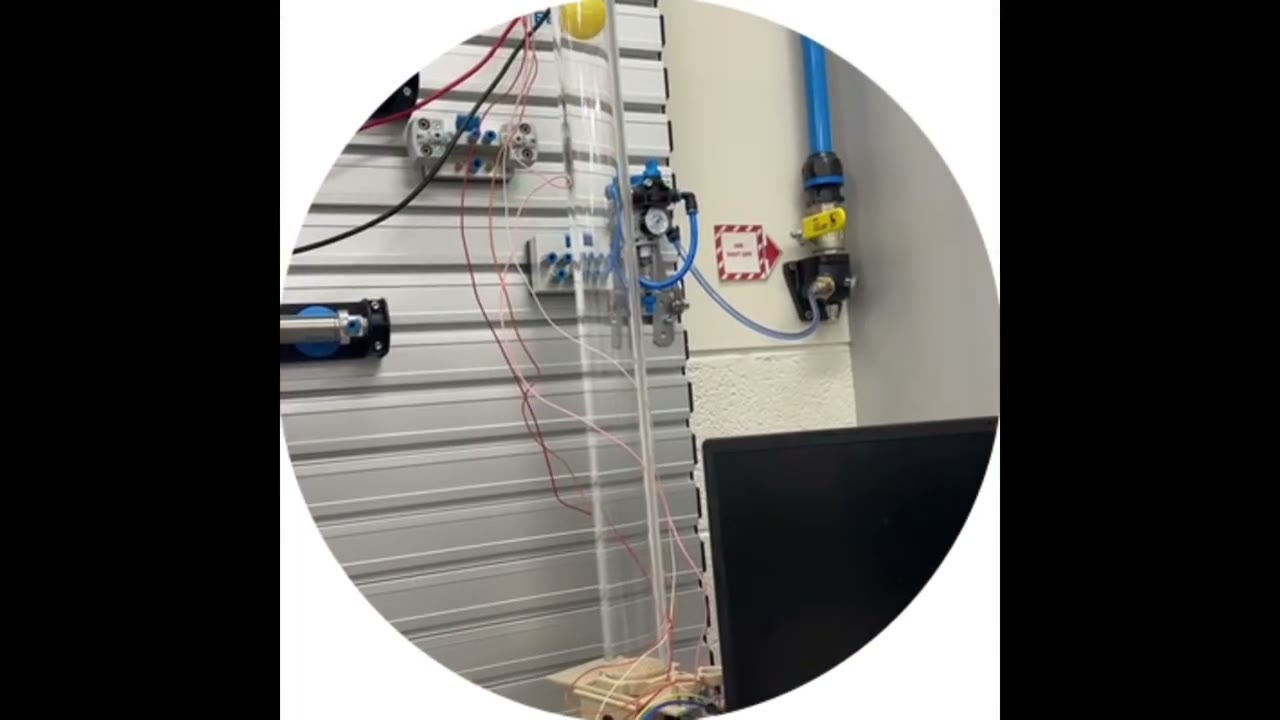
Integrated Arduino sensing with a Siemens PLC over Modbus TCP and tuned PID control in a team-built fan levitation system, maintaining ball height within ±3 mm with a 10-second settling time.
The reaction cube optimiser ranks successful simulation runs using weighted min–max normalisation. The current flywheel routine balances component mass, tipping time and target RPM, then refines candidate parameters around the best tested design. The result depends on the model, tested candidates and selected weights; it is not a claim of a global optimum.
Read moreSmartbreadboard separates low-level switch control from the longer-term goal of routing complete circuit connections. The current work covers PCB design, Arduino firmware and addressing/control-signal checks. Automatic routing and full electrical characterisation remain development work.
Read moreCarlow Toolmaking Services — January – May 2026
Produced and updated tool CAD in Solid Edge, maintaining drawing versions and manufacturing documentation for machining. Supported wire EDM setup and CNC milling within the workshop team, applying guidance from toolmaking and machining specialists.
Insoftex — February – August 2024
Developed a solar monitoring website with a software team using Svelte and JavaScript to collect and visualise energy output and system performance. Retrieved location and address information from satellite feeds for the monitoring project.
South East Technological University — September 2024 – present
Co-founded and chaired a chess club with 25+ active members, built a team, and organised weekly sessions, tournaments and university events.
South East Technological University —
Co-founded the university Astronomy Club.
BEng (Hons) in Robotics and Automated Systems
South East Technological University, Carlow, Ireland, 2023 – May 2027 (expected)
Studies in Computer Science and Internet of Things
Lviv Polytechnic National University, Ukraine, September 2021 – May 2023
Programming & analysis: Python, C/C++, MATLAB, Simulink, JavaScript/TypeScript
Control & embedded systems: Siemens TIA Portal, S7-1500 PLC, PID, Arduino, Modbus TCP, I2C
Design & electronics: SolidWorks, Fusion 360, Solid Edge, 3D printing, KiCad, Proteus, Logic analyser